汉堡
关闭
English
Search
路径
Robotic Core Drive Components​​​​​​​
Humanoid Robots​​​​​​​
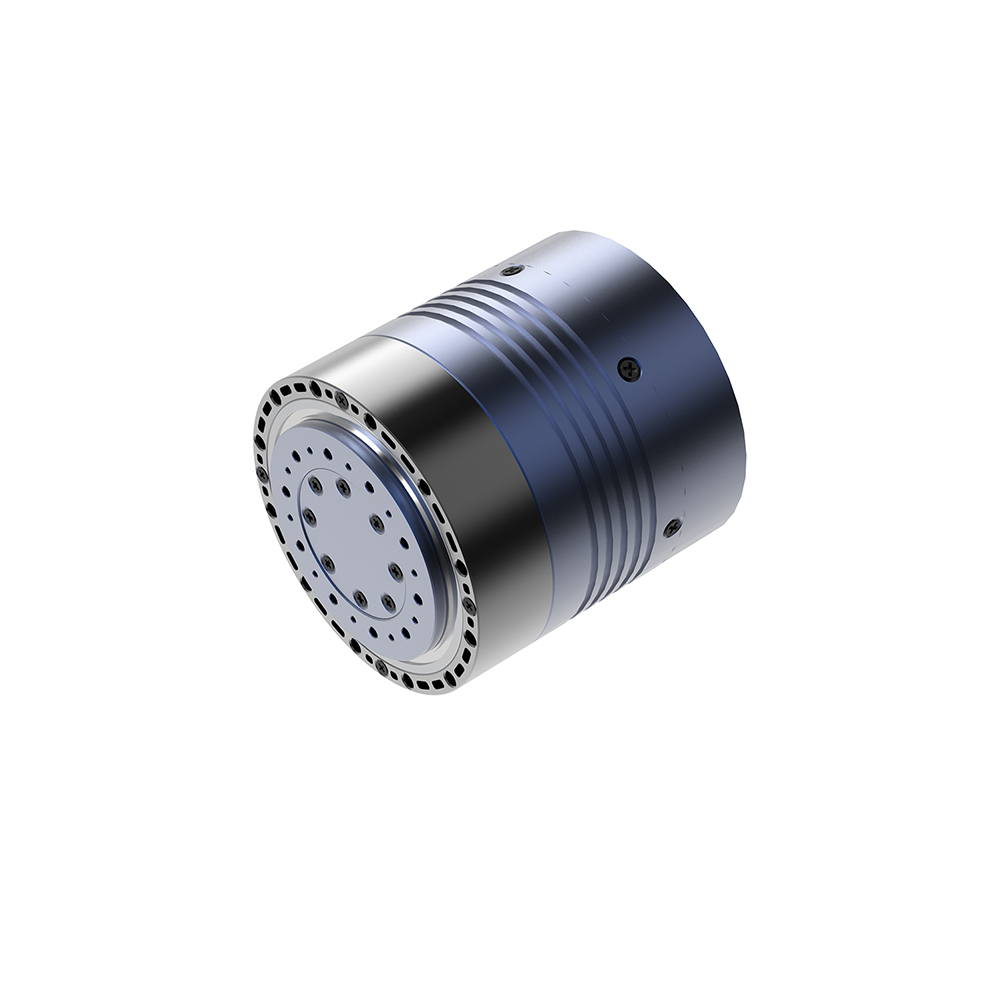
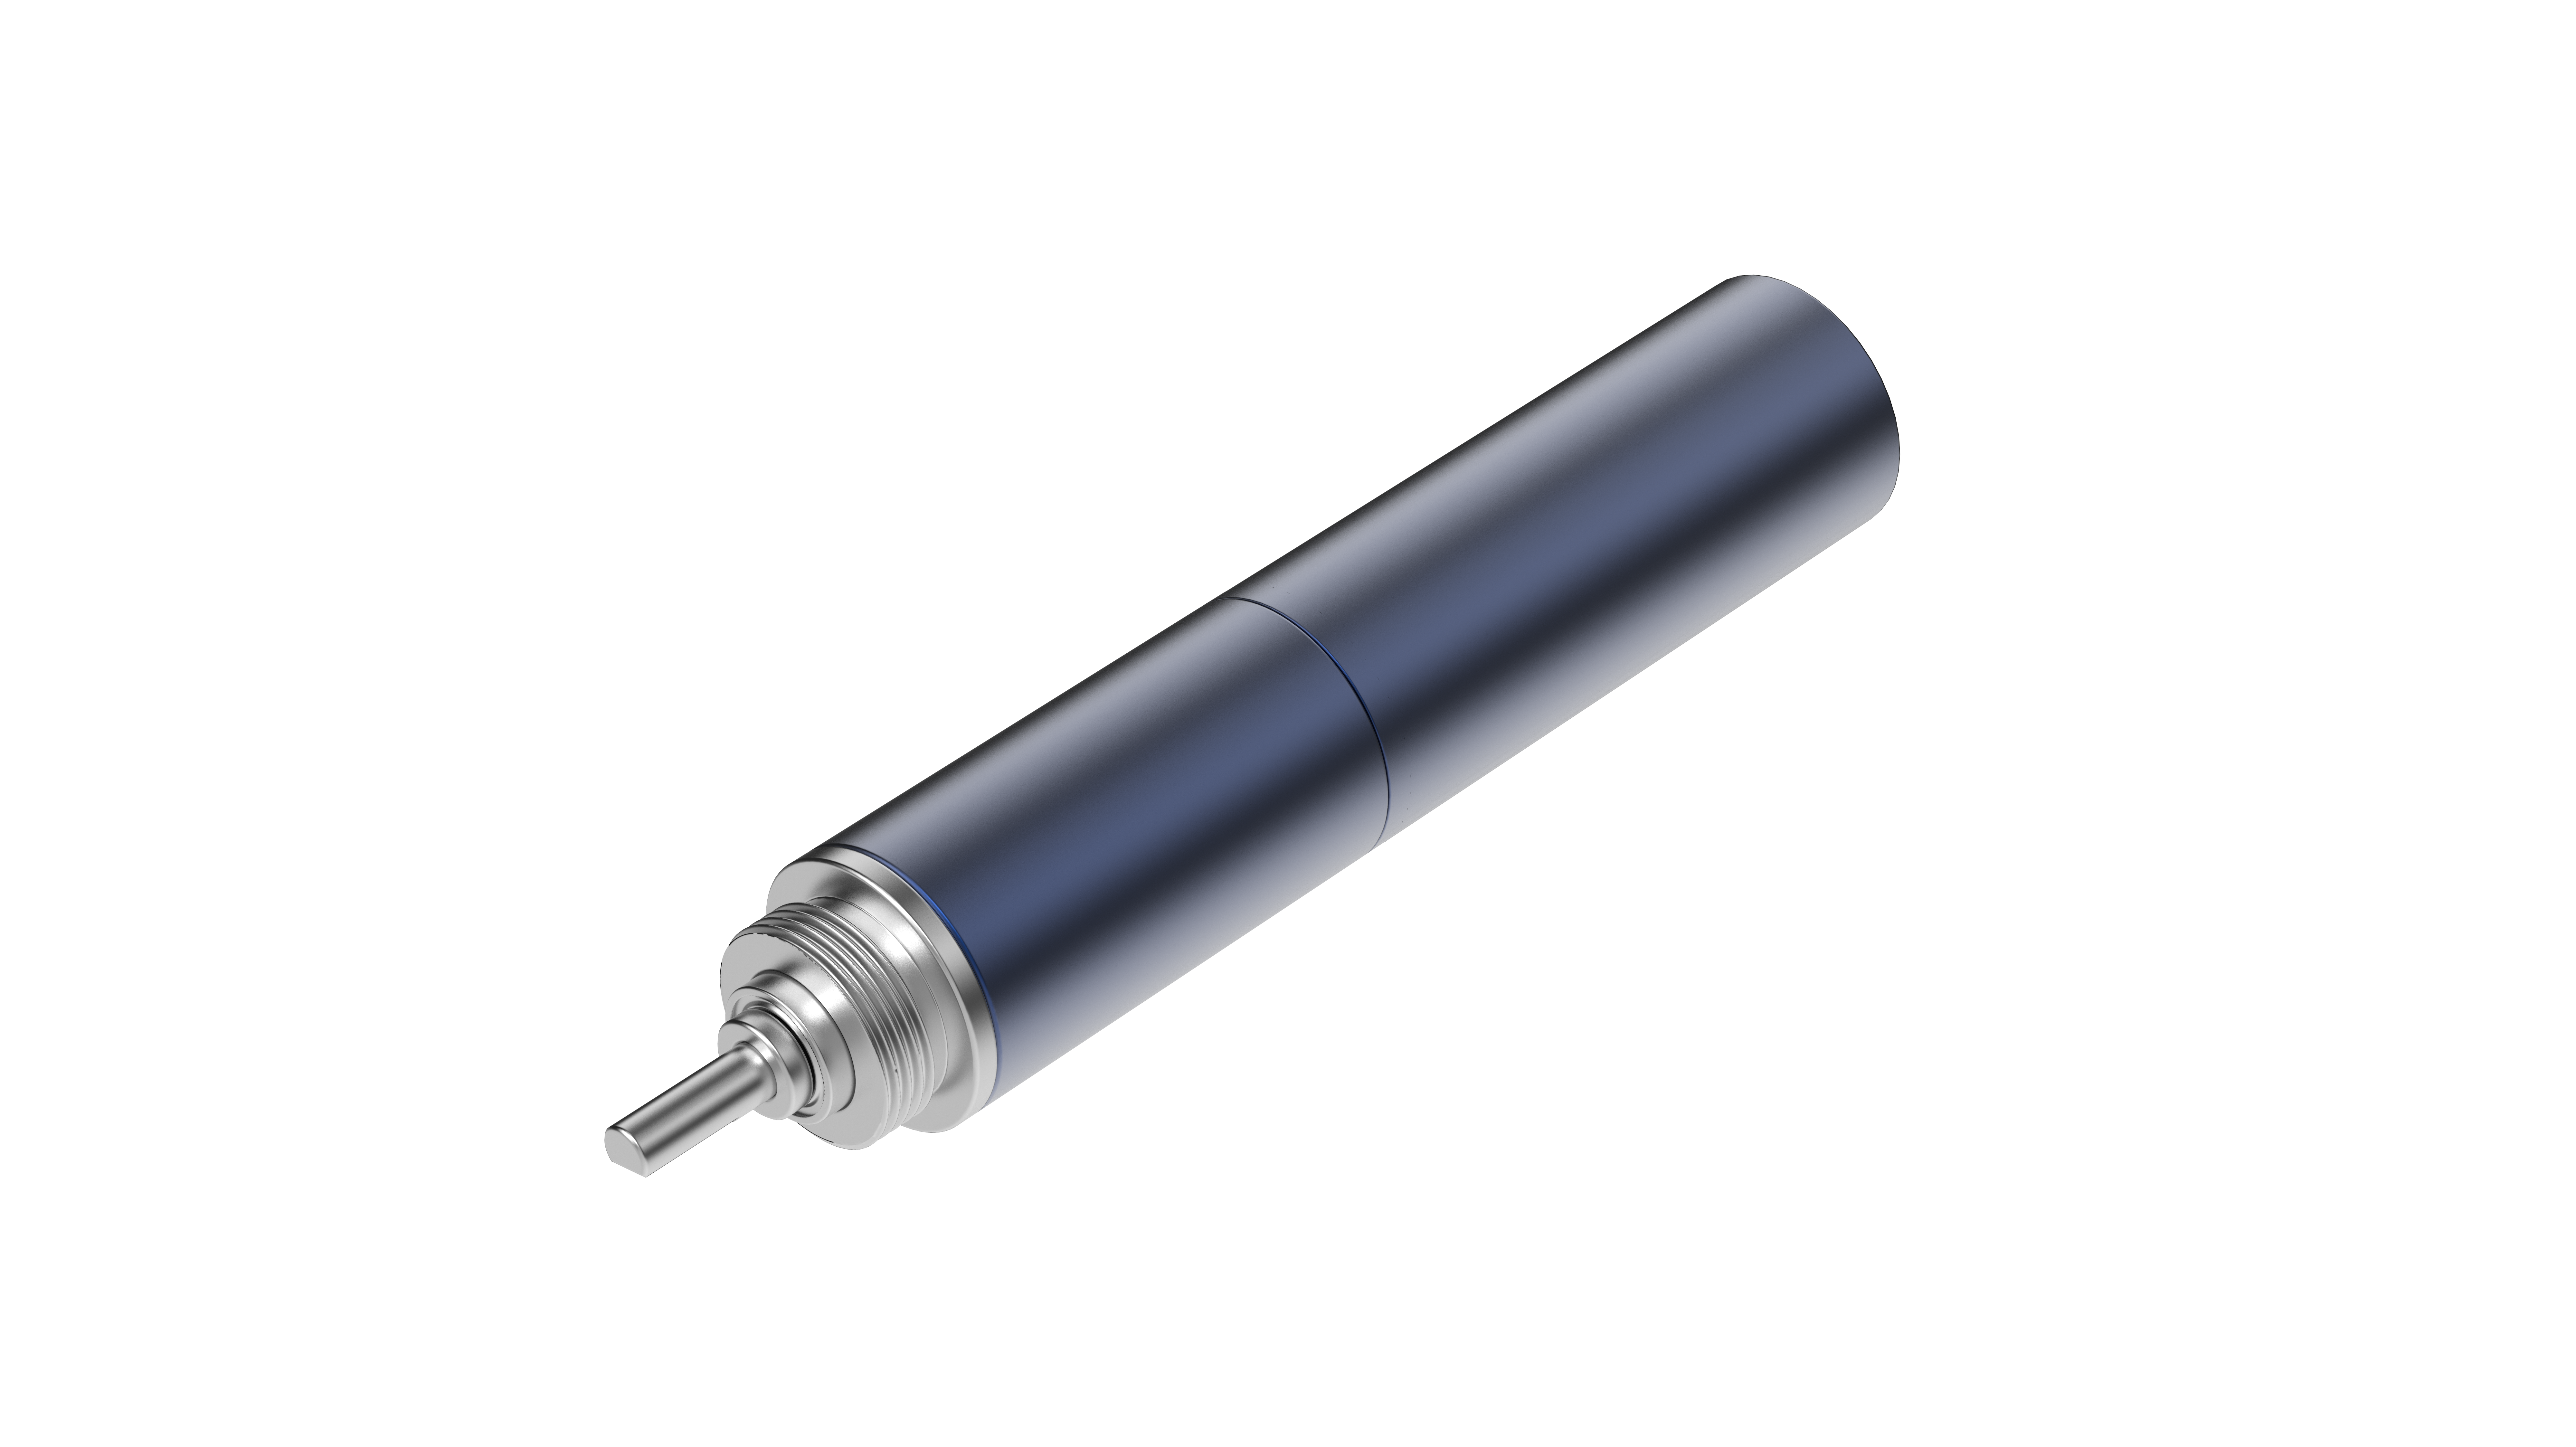
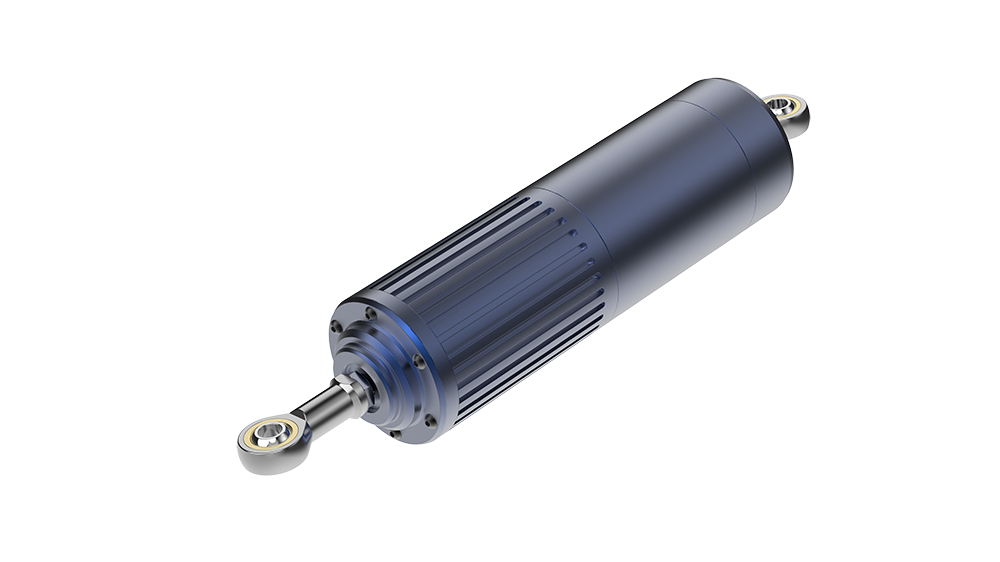
For full-body joint applications in humanoid robots, JIECANG has developed a comprehensive portfolio of core drive components, including rotary joint modules, linear actuators, frameless torque motors, and coreless motor assemblies, covering key motion joints such as the shoulders, elbows, wrists, hips, knees, and ankles.

Leveraging lightweight materials, high torque density, high-precision transmission, and highly integrated design, JIECANG continuously enhances the power performance, motion flexibility, and space utilization of robotic joints. These advanced drive technologies provide the core driving force for lighter, more efficient, and more agile full-body motion, enabling humanoid robots to achieve greater mobility and performance.​​​​​​​

下拉箭头小
收起箭头

Related Products

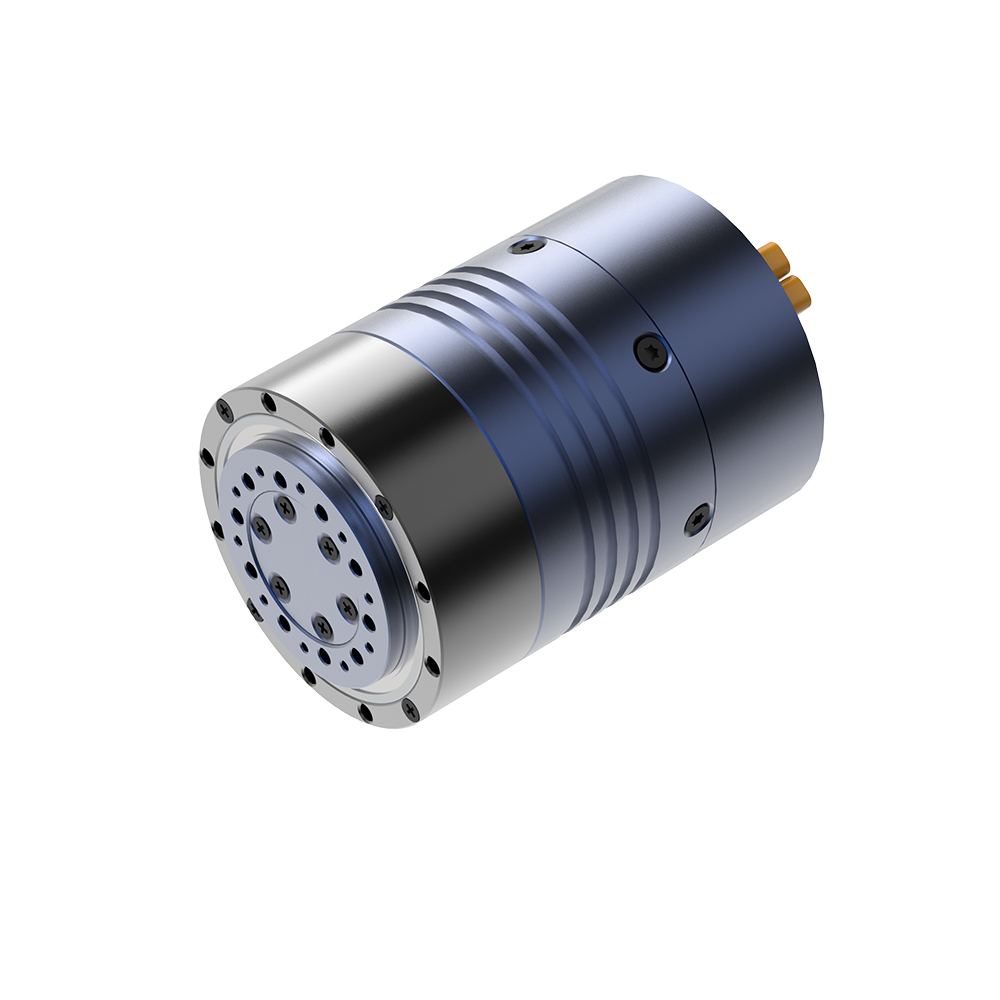
Harmonic Module
Dimensions:ø50x67mm
Rated / Peak Torque:10 / 30N·m
Rated Speed:37.5rpm
Weight:0.4kg
Harmonic Module
Dimensions:ø60x73.5mm
Rated / Peak Torque:30 / 90N·m
Rated Speed:37.5rpm
Weight:0.7Kg
Harmonic Module
Dimensions:ø70x76mm
Rated / Peak Torque:60 / 180N·m
Rated Speed:30rpm 
Weight:1.0kg

Related Cases

Robotic

Summary: As humanoid robotic joints become more compact, simple weight reduction is no longer enough. This article explores Jiecang's systemic approach to lightweighting—featuring double-steel-wheel harmonic drives, advanced polymer cycloidal modules, and liquid-cooled systems—ensuring optimal torque, precision, and thermal stability in modern rotary actuators.

Robotic

At WAIC 2026, JIECANG presented its advanced robotic drive portfolio, offering highly reliable and customizable actuator solutions for global robotics innovators.

QUICK LINKS

QUICK LINKS

COMPONENTS

COMPONENTS

SYSTEMS

SYSTEMS

  Add: No.2 Laisheng Road, Provincial High-tech industrial park, Xinchang county, Zhejiang province, China
 Copyright   2022 Jiecang Sitemap | Privacy Policy